Chaining Visuomotor Skills for Constrained Manipulation
Through Perceptual Manipulation

Anonymous Authors

Under review

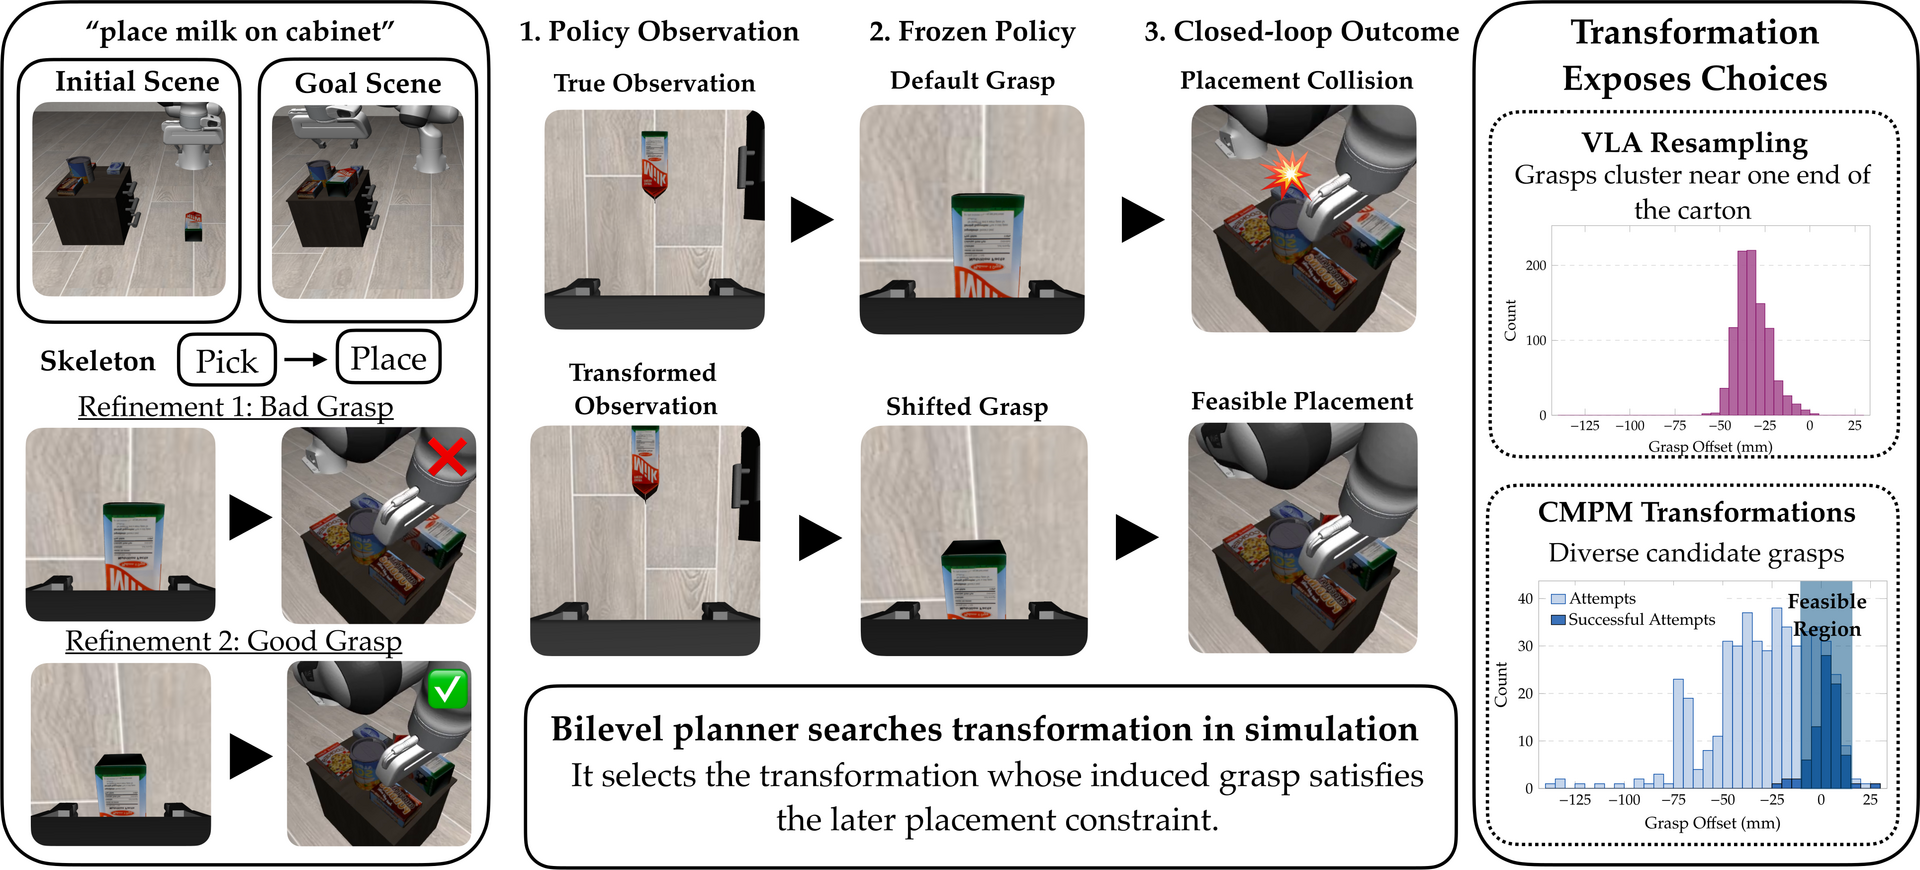
Placing milk on a cabinet. The frozen policy's default grasp leads to a placement
                collision; a transformed observation induces a shifted grasp and a feasible
                placement. A bilevel planner searches transformations in simulation, and the grasp
                offsets it reaches are far more diverse than those from resampling the policy.
Teaser caption.

Abstract

Abstract goes here.

Method

Method summary goes here.
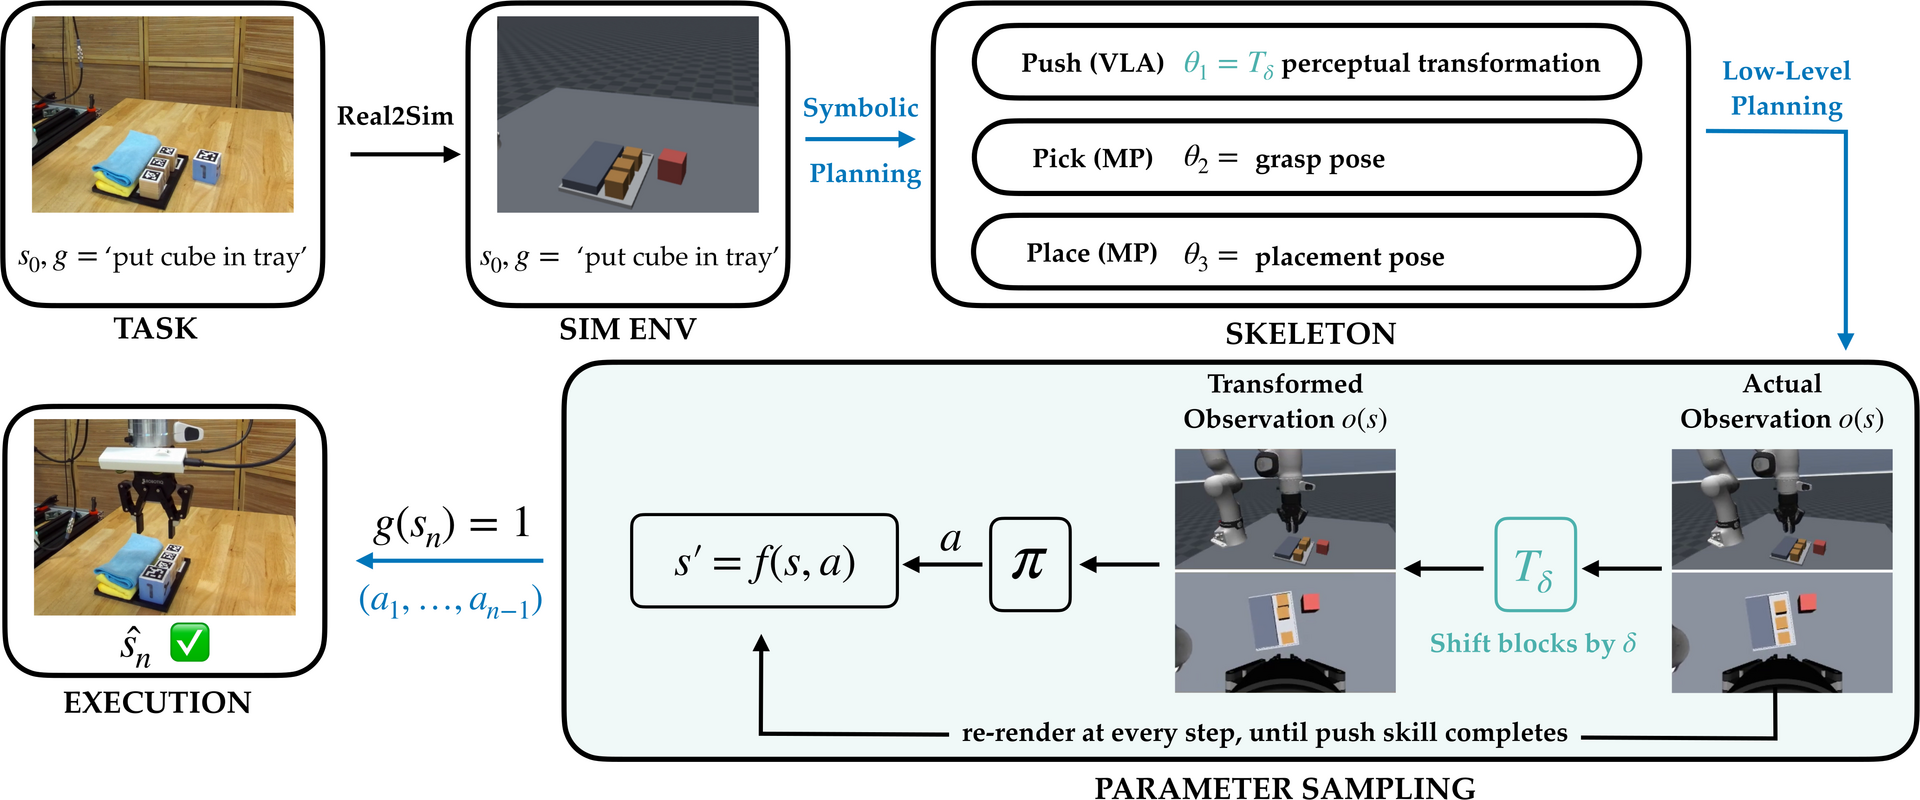
Method overview: a task is transferred real-to-sim, a symbolic planner produces a
                skill skeleton whose parameters include a perceptual transformation, and low-level
                planning samples those parameters by rolling out the policy on transformed
                observations.
Pipeline caption.

Tasks

Task overview goes here.

figure
Task one.
figure
Task two.
figure
Task three.
figure
Task four.

Results

Results summary goes here.

results figure
Results caption.

Videos

Rollout description goes here.

video
Rollout one.
video
Rollout two.
video
Rollout three.

BibTeX

@inproceedings{anonymous,
  title     = {Chaining Visuomotor Skills for Constrained Manipulation
               Through Perceptual Manipulation},
  author    = {Anonymous},
  booktitle = {},
  year      = {}
}